Open Source
WildOS: Open-Vocabulary Object Search in the Wild
arXiv cs.RO0 views
arXiv:2602.19308v2 Announce Type: replace Abstract: Autonomous navigation in complex, unstructured outdoor environments requires robots to operate over long ranges without prior maps and limited depth sensing. In such settings, relying solely on geometric frontiers for exploration is often insufficient. In such settings, the ability to reason semantically about where to go and what is safe to traverse is crucial for robust, efficient exploration. This work presents WildOS, a unified system for long-range, open-vocabulary object search that combines safe geometric exploration with semantic visual reasoning. WildOS builds a sparse navigation graph to maintain spatial memory, while utilizing a foundation-model-based vision module, ExploRFM, to score frontier nodes of the graph. ExploRFM simultaneously predicts traversability, visual frontiers, and object similarity in image space, enabling real-time, onboard semantic navigation tasks. The resulting vision-scored graph enables the robot to explore semantically meaningful directions while ensuring geometric safety. Furthermore, we introduce a particle-filter-based method for coarse localization of the open-vocabulary target query, that estimates candidate goal positions beyond the robot's immediate depth horizon, enabling effective planning toward distant goals. Extensive closed-loop field experiments across diverse off-road and urban terrains demonstrate that WildOS enables robust navigation, significantly outperforming purely geometric and purely vision-based baselines in both efficiency and autonomy. Our results highlight the potential of vision foundation models to drive open-world robotic behaviors that are both semantically informed and geometrically grounded. Project Page: https://leggedrobotics.github.io/wildos/
Source:https://arxiv.org/abs/2602.19308PreviousEquiContact: A Hierarchical SE(3) Vision-to-Force Equivariant Framework for Spatially Generalizable Contact-rich TasksNextCHOP: Counterfactual Human Preference Labels Improve Obstacle Avoidance in Visuomotor Navigation Policies
Related posts
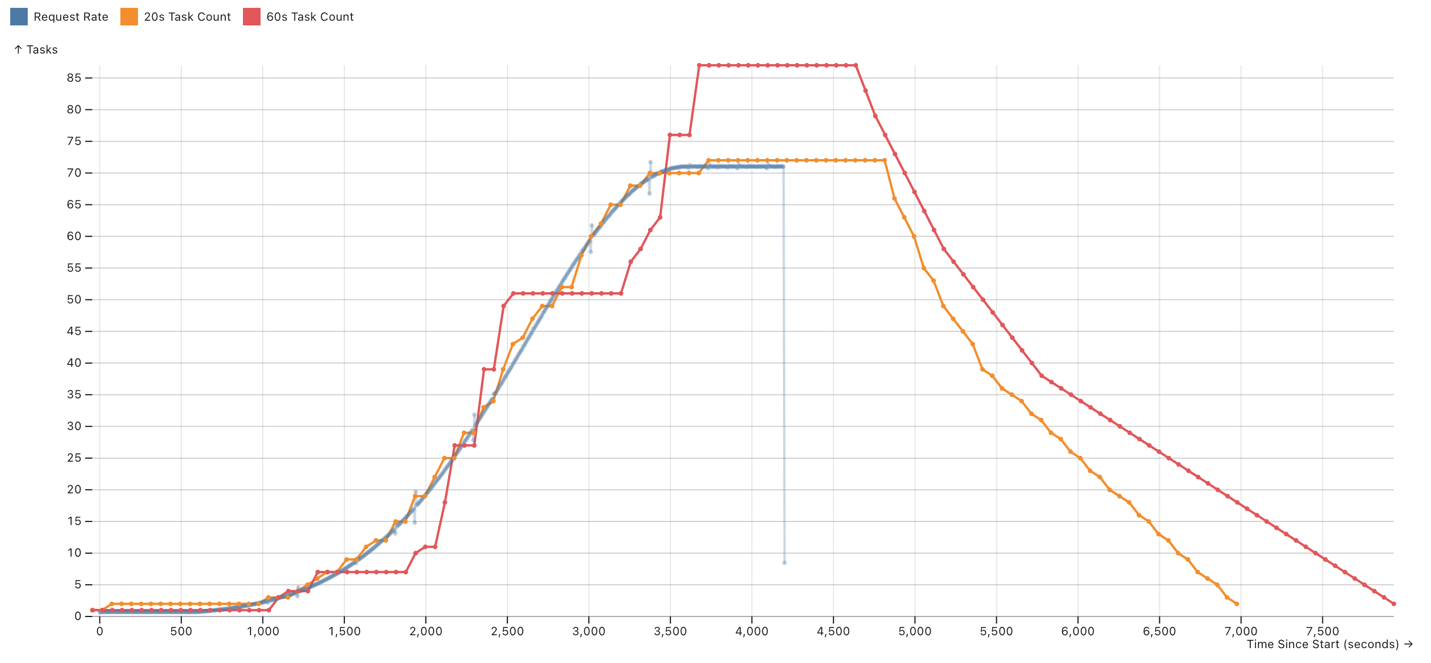
Deep dive: Auto scaling response times on Amazon ECS
0AWS Containers Blog

10 Hours to 3: How KAIST's CluSTER Picks the 31% of Data That Actually Teaches
0dev.to Machine Learning

25 Pattern Problems Later: What I Learned About Loops in C++
0dev.to Beginners

Ozempic and Wegovy linked to rare risk of sudden vision loss
0dev.to Programming

Me and Git: A Love Story That Never Started.
0dev.to Programming
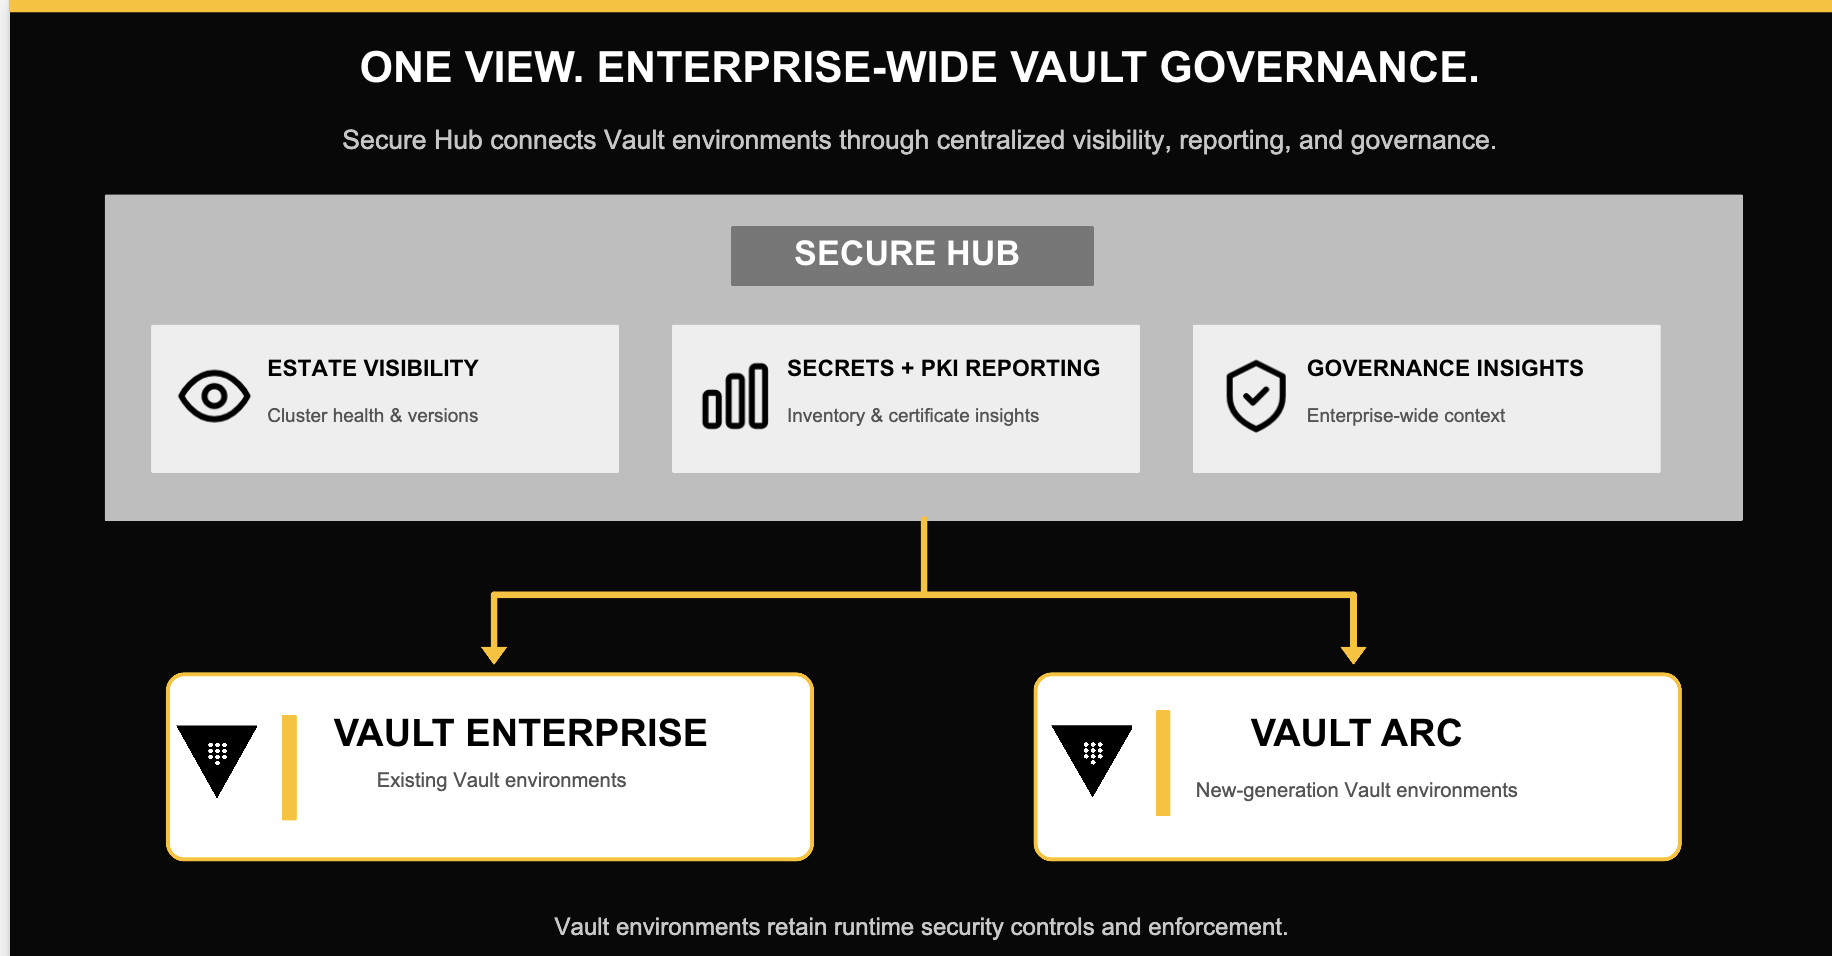
Announcing the public preview of HashiCorp Secure Hub: Govern Vault at scale
0HashiCorp Blog