Open Source
Autonomous Whole-body Loco-manipulation Using a Snake Robot
arXiv eess.SY0 views
arXiv:2611.09777v1 Announce Type: cross Abstract: Snake robots can leverage their hyper-redundant morphology for both locomotion and manipulation through distributed body contact but whole-body loco-manipulation is particularly challenging since the entire body serves simultaneously as propulsive mechanism and manipulation tool Prior work on wheeled legged and snake robot platforms has decoupled these functions through dedicated appendages body segmentation or grippers We present closed-loop loco-manipulation with our snake robot COBRA without this distinction such that any part of the body may make contact We develop a contact-implicit dynamic model unifying robot-ground robot-object and object-ground interactions within a Moreau-Jean time-stepping framework and formulate a trajectory optimization over the full-order dynamics guided by a geometric planner and nominal proportional controller to autonomously push an object to a goal location during sidewinding We validate the planner and controller on hardware across varied configurations and present simulation results for a simplified trajectory optimization that resolves robot-object and object-ground contacts
Source:https://arxiv.org/abs/2611.09777PreviousA Cross-Domain TARA-to-NAC Rule Mapping Methodology: From Automotive OEM Networks to Energy Storage SystemsNextGeometric Pairwise Classification of Affine Constraints over Ellipsoidal Regions
Related posts

Open Cluster Management (OCM) becomes a CNCF Incubating Project
0CNCF Blog
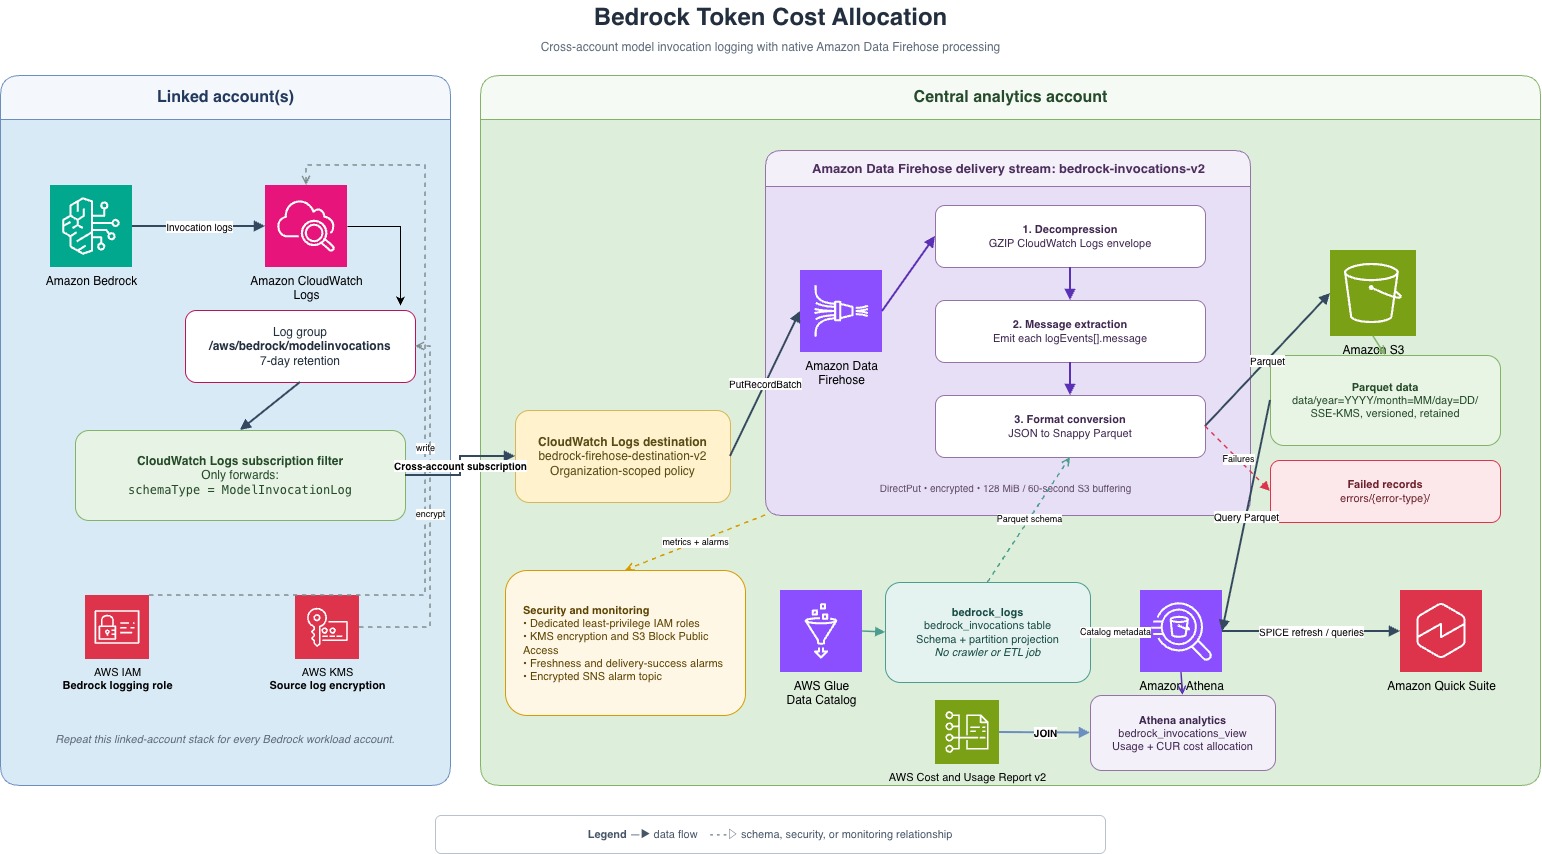
Amazon Bedrock tokenomics data lake
0AWS Machine Learning Blog

Tell HN: Agent that control everyscreen beat human in clash royale
0Hacker News Ask

Weird licenses and the new open source
0Lobsters
Announcing the Swift Student Challenge 2027
0Apple Developer News

High oil prices have led to a dip in global carbon emissions
0Ars Technica