AI & ML
DeRep: Learning Depth Representations for End-to-End Navigation in Cluttered Environments
arXiv cs.RO0 views
arXiv:2611.13499v1 Announce Type: new Abstract: End-to-end navigation in cluttered environments relies on compact visual representations to support collision avoidance and goal-directed motion. Existing methods typically learn these representations jointly with the policy or through observation reconstruction, which does not explicitly specify what information the representation should preserve. Moreover, they are usually evaluated with a single downstream policy learner, although the benefit of a representation may depend on how the policy is learned. It therefore remains unclear how different representation-learning objectives affect downstream navigation performance and robustness. This work proposes DeRep, a navigation-oriented representation-learning method that combines local bird's-eye-view reachability supervision with depth reconstruction. To compare representation objectives under controlled conditions, we pretrain encoders with a common architecture and freeze them during downstream learning. We evaluate the representations using a linear policy probe, flow-matching imitation learning, and reinforcement learning with PPO. DeRep achieves the lowest linear policy probe prediction error and outperforms reconstruction alone across all six tested PPO conditions. In imitation learning, both reachability-based objectives achieve higher mean success rates than reconstruction alone, with similar mean success rates between the reachability-only and joint objectives. These results demonstrate consistent benefits of incorporating reachability supervision into depth representation pretraining across different downstream learning methods and evaluation conditions. We further deploy the PPO policy with the frozen DeRep encoder in Gazebo and on a physical quadrotor without fine-tuning, demonstrating its capability for zero-shot sim-to-sim and sim-to-real transfer.
Source:https://arxiv.org/abs/2611.13499PreviousRoute-Time Conflict Maps for Cooperative End-to-End Autonomous DrivingNextDifferentiable Filtering for Inertial Odometry
Related posts

HPE7-A11 Exam: A Design-Artifact Guide to Campus Access Architecture
0dev.to

Railway's Breach Cost $740,000 in Fraudulent AI Charges — and Up to 100,000 Workspaces May Have Leaked Secrets
0dev.to

Nod Reports 98% Agent Task Completion and 93.2% Long-Term Memory Recall in Tests
0dev.to

How to get business location data for a whole US state in bulk
0dev.to

OpenAI Cost Tracking Middleware: Build a Logging Wrapper That Shows Every Call's Price
0dev.to
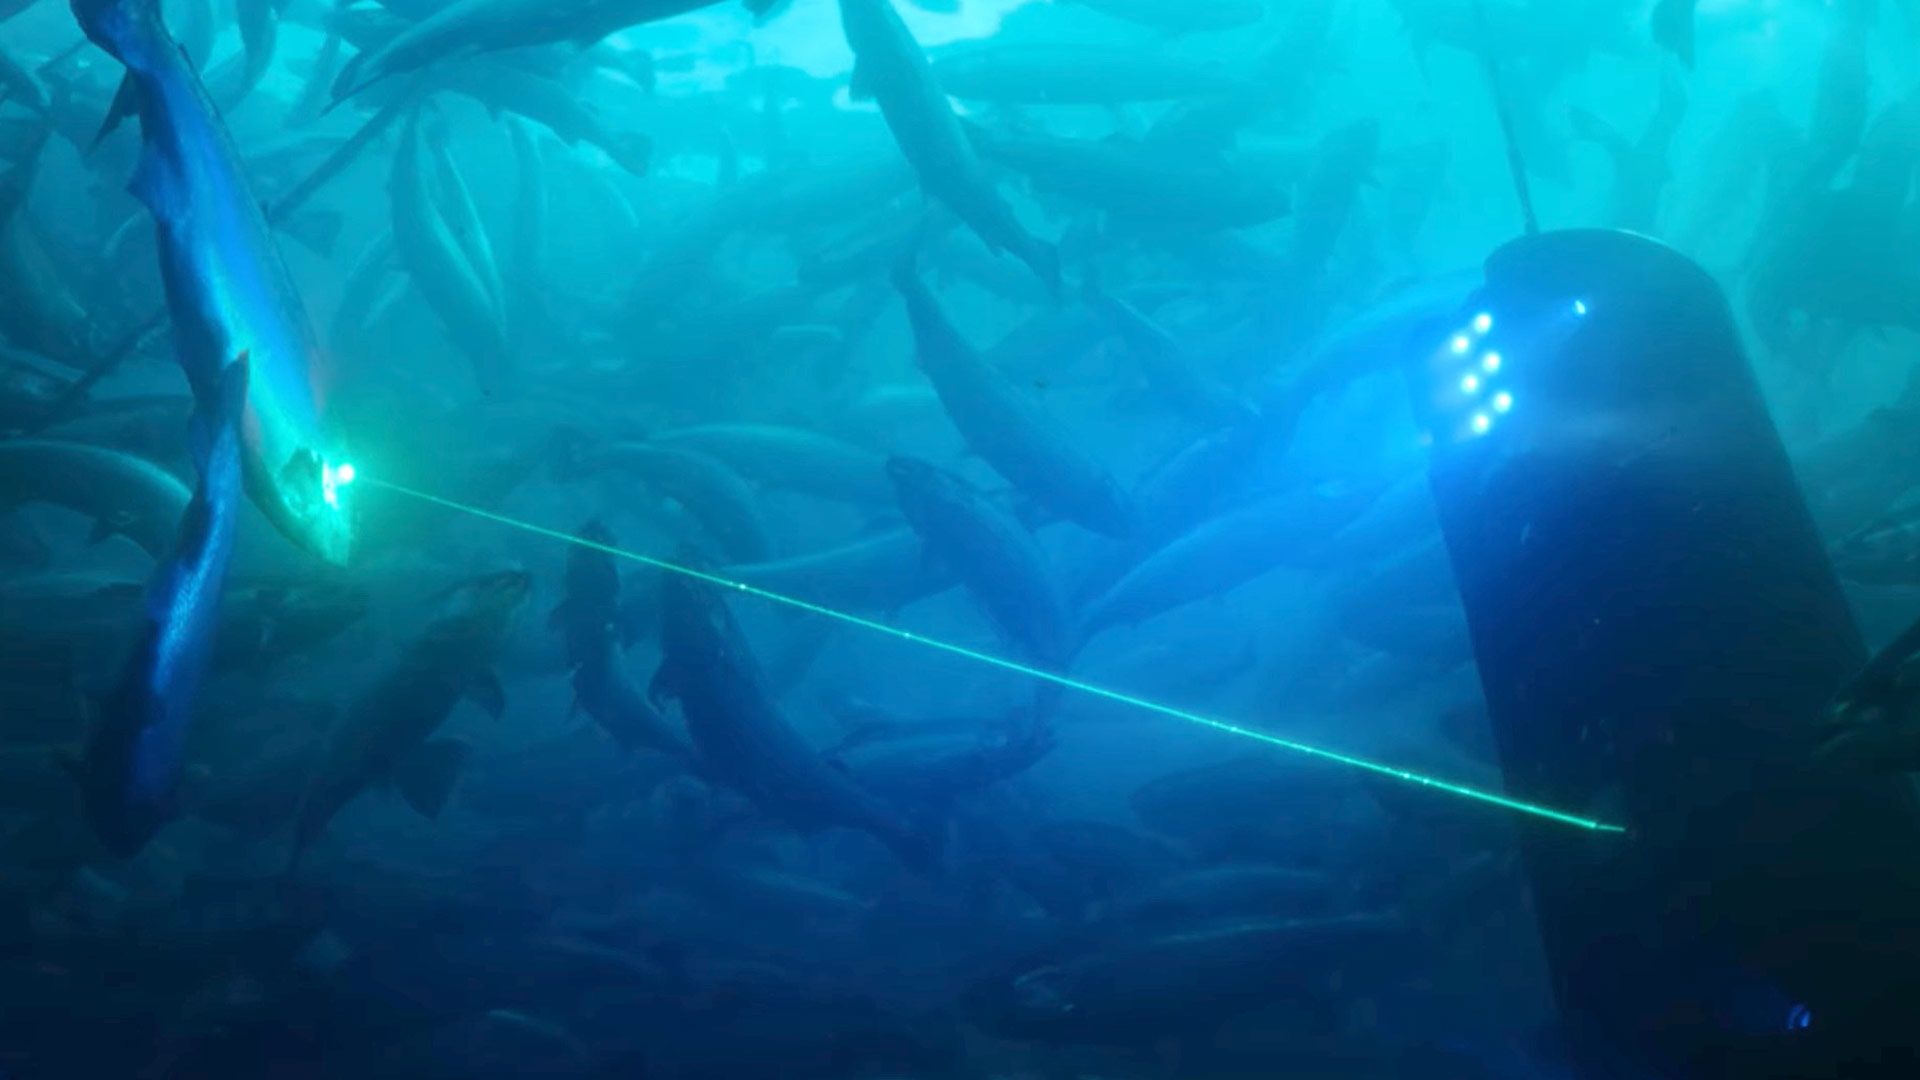
3,500 laser-armed AI submarine drones patrol Norwegian salmon farms, killing sea lice and protecting 112 million fish
0Tom's Hardware