AI & ML
Galilean Symmetry in Robotics
arXiv cs.RO0 views
arXiv:2510.10468v2 Announce Type: replace Abstract: In this paper, we present a robotics-tailored exposition of Galilean symmetry that leverages the community's familiarity with and understanding of rigid-body transformations and pose representations. Our approach contrasts with common treatments in the physics literature that introduce Galilean symmetry as a stepping stone to Einstein's relativity. We show that the classical homogeneous matrix algebra known well to roboticist translates directly into the Galilean modeling framework and provides a powerful tool for tackling robotics problems involving inertial measurements and spatio-temporal variables. We demonstrate the potential of the approach by developing a powerful model for studying motion of vehicles in an Earth fixed rotating reference frame, and developing a fusion algorithm for measurements with uncertain time-stamps.
Source:https://arxiv.org/abs/2510.10468PreviousLearning Latent Volumetric Dynamics for Multimodal Goal-Conditioned Robot Manipulation of HairNextControllable Generative Trajectory Prediction via Weak Preference Alignment
Related posts

Five of my most-read catalog pages 404 because of a hyphen I never chose
0dev.to Database
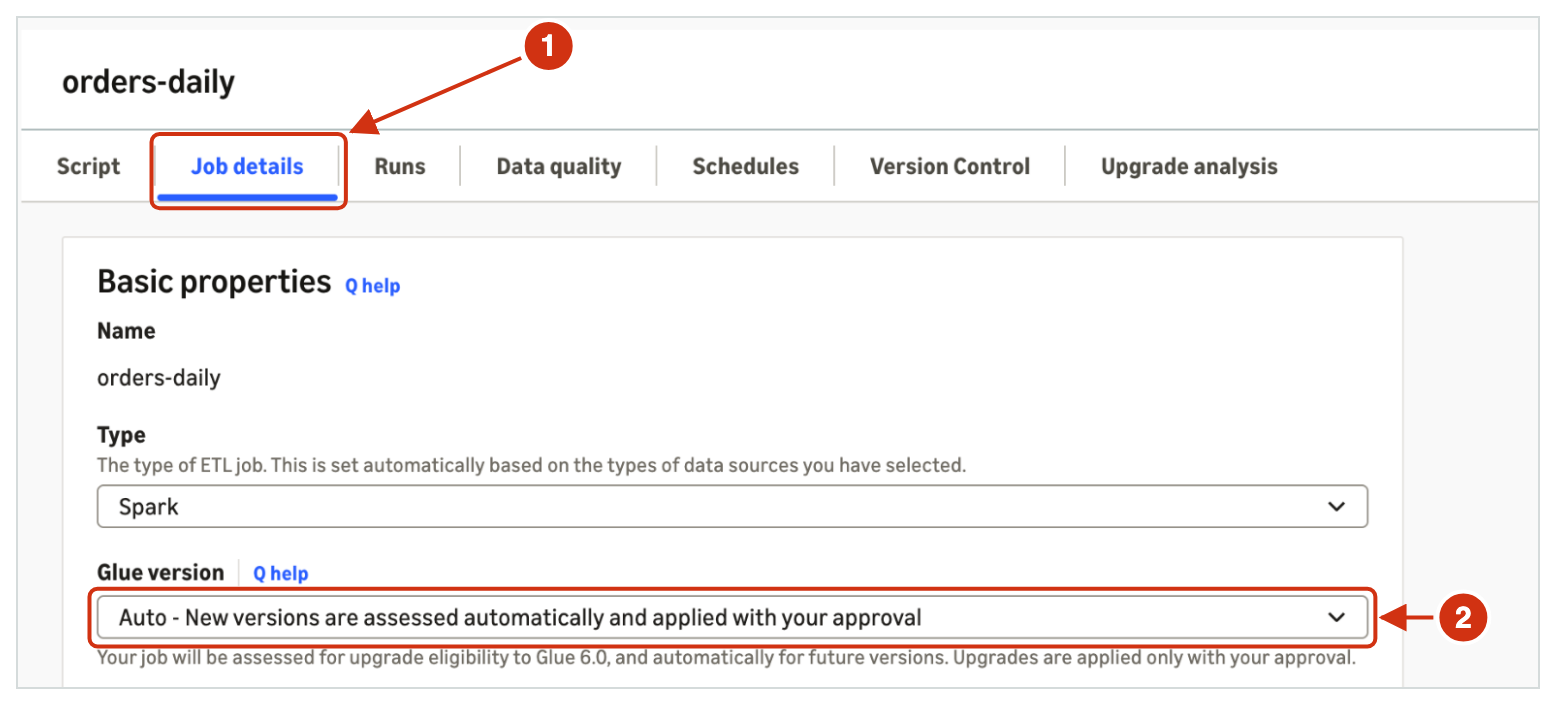
Introducing automatic version upgrades for AWS Glue jobs
0AWS Big Data Blog
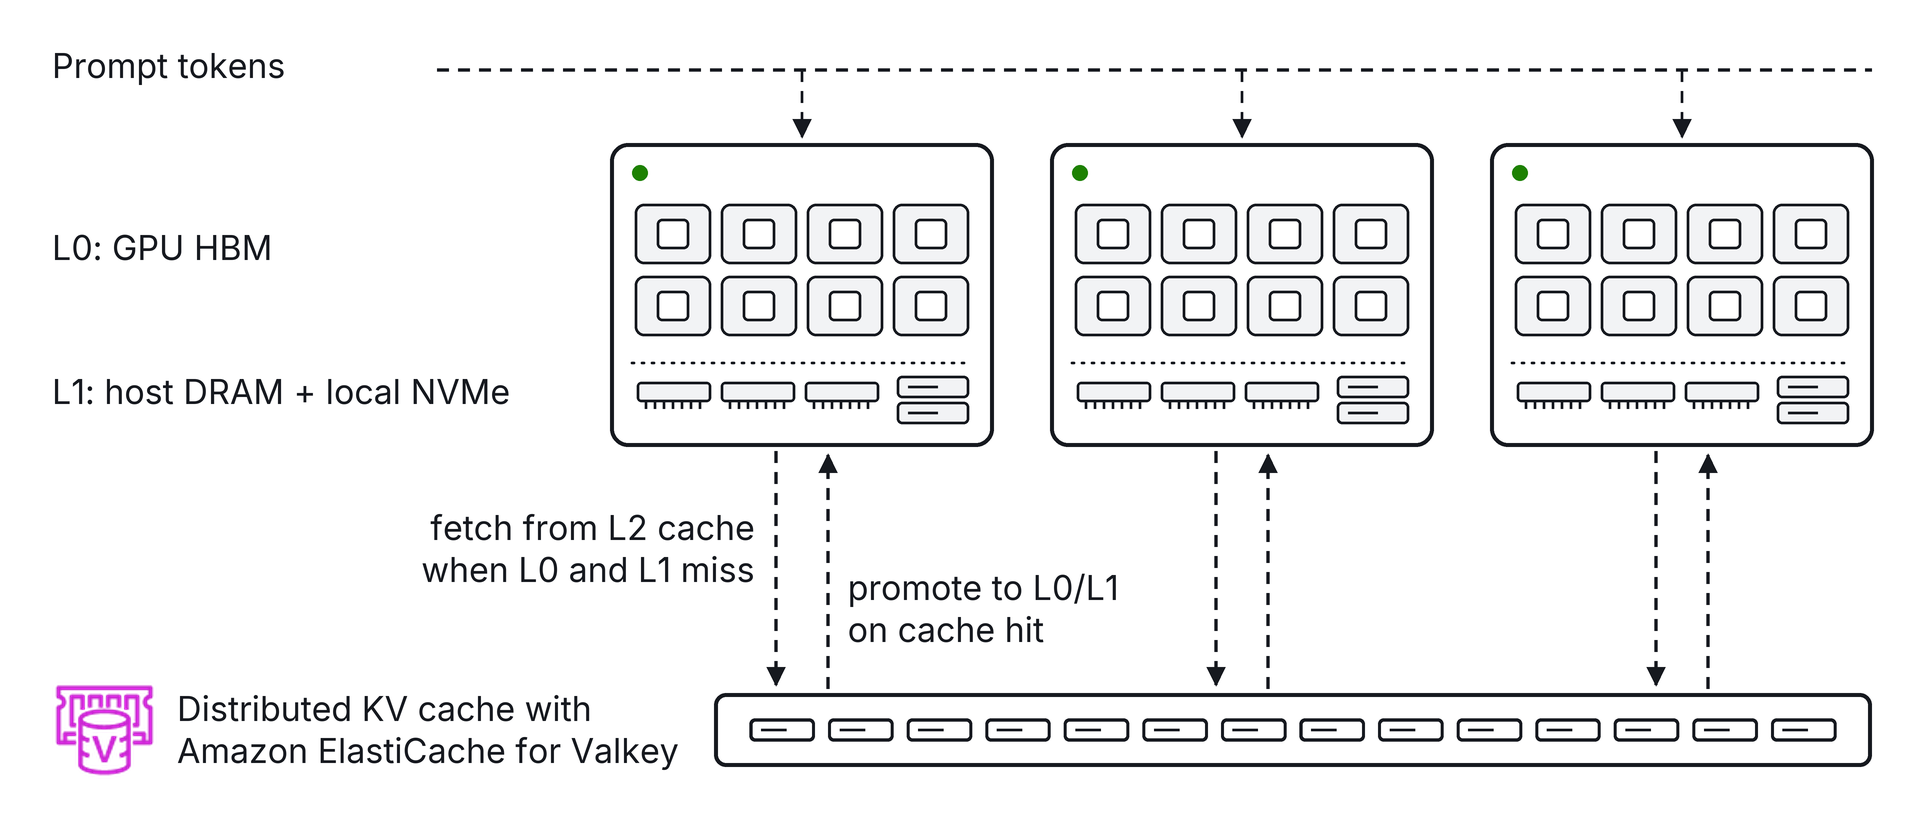
Announcing distributed KV caching for self-hosted LLMs with Amazon ElastiCache
0AWS Database Blog
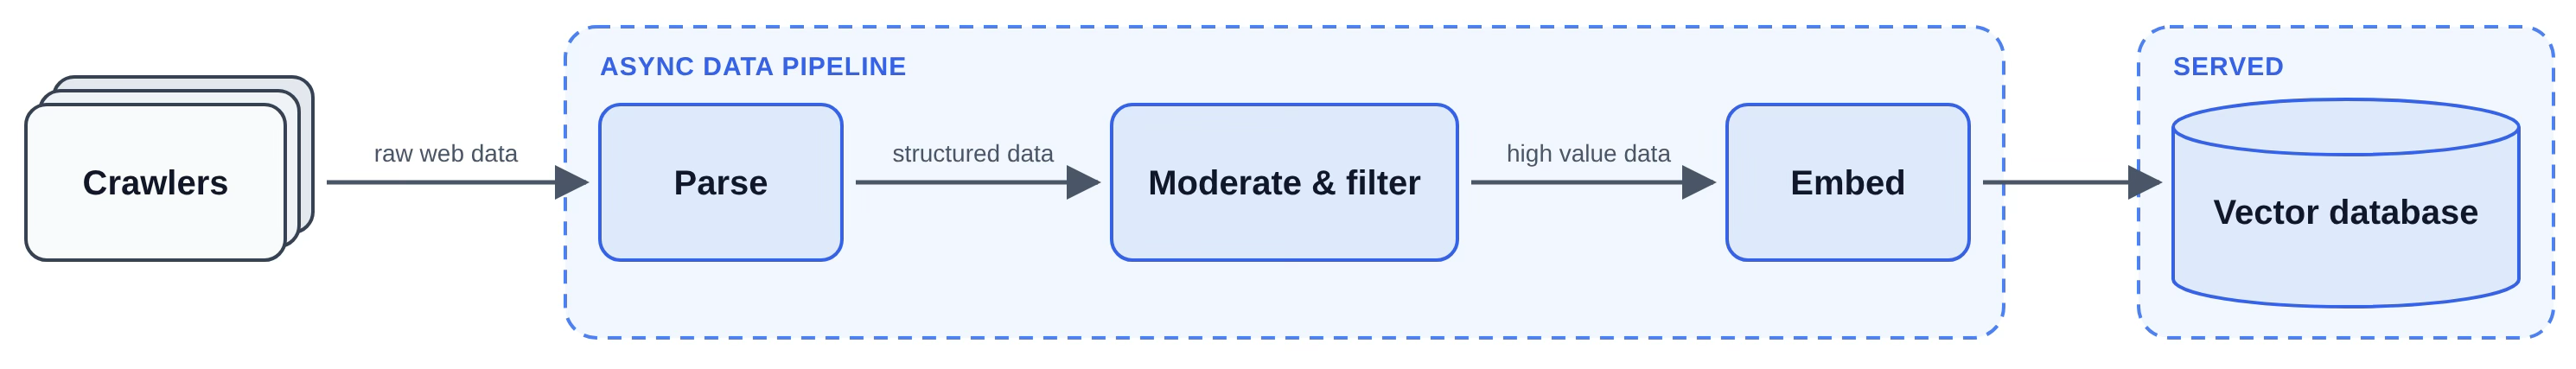
Exa boosts embedding throughput by 50% to index billions of documents on AWS AI chips
0AWS Machine Learning Blog

BEVCast: Path-Adaptive BEV for Efficient End-to-End Autonomous Driving
0arXiv cs.RO

World-Model Gradient Refinement in CEM: An Empirical Study
0arXiv cs.RO