AI & ML
Dynamic Multi-Robot Task Allocation under Uncertainty and Communication Constraints: A Game-Theoretic Approach
arXiv cs.RO0 views
arXiv:2604.11954v2 Announce Type: replace-cross Abstract: We study dynamic multi-robot task allocation under uncertain task completion, time-window constraints, and incomplete information. Tasks arrive online over a finite horizon and must be completed within specified deadlines, while agents operate from distributed hubs with limited sensing and communication. We model incomplete information through hub-based sensing regions that determine task visibility and a communication graph that governs inter-hub information exchange. Using this framework, we propose Iterative Best Response (IBR), a decentralized policy in which each agent selects the task that maximizes its marginal contribution to the locally observed welfare. We compare IBR against three baselines: Earliest Due Date first (EDD), Hungarian algorithm, and Stochastic Conflict-Based Allocation (SCoBA), on a city-scale package-delivery domain with up to 100 drones and varying task arrival scenarios. Under full and sparse communication, IBR achieves competitive task-completion performance with lower computation time.
Source:https://arxiv.org/abs/2604.11954PreviousSpatial Calibration of Diffuse LiDARsNextAAC: Admissible-by-Architecture Differentiable Landmark Compression for ALT
Related posts
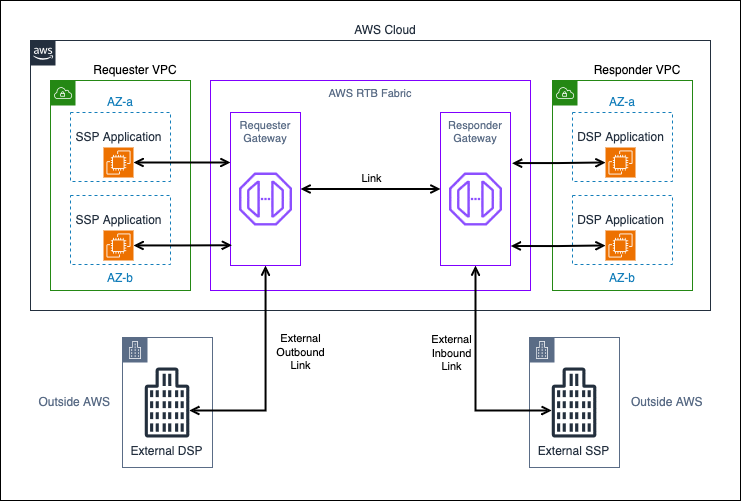
Building highly available real-time bidding workloads with AWS RTB Fabric
0AWS for Industries

Thống kê đối đầu Rayo Vallecano vs Valencia: Xu thế bế tắc và quy luật chia điểm áp đảo
0dev.to Data

Phân tích dữ liệu đối đầu Alaves vs Deportivo La Coruna: Ưu thế phòng ngự tuyệt đối của đại diện xứ Basque
0dev.to Data

Thống kê đối đầu Arsenal vs Newcastle: Thế trận phân định tuyệt đối và dấu ấn phòng ngự
0dev.to Data

Tương quan thông số vòng 8 V.League 1: Thể Công - Viettel chạm trán Sông Lam Nghệ An
0dev.to Data

Into the Breach: Show the Threat, Not the Answer
0dev.to Design