AI & ML
Galilean Symmetry in Robotics
arXiv cs.RO0 views
arXiv:2510.10468v2 Announce Type: replace Abstract: In this paper, we present a robotics-tailored exposition of Galilean symmetry that leverages the community's familiarity with and understanding of rigid-body transformations and pose representations. Our approach contrasts with common treatments in the physics literature that introduce Galilean symmetry as a stepping stone to Einstein's relativity. We show that the classical homogeneous matrix algebra known well to roboticist translates directly into the Galilean modeling framework and provides a powerful tool for tackling robotics problems involving inertial measurements and spatio-temporal variables. We demonstrate the potential of the approach by developing a powerful model for studying motion of vehicles in an Earth fixed rotating reference frame, and developing a fusion algorithm for measurements with uncertain time-stamps.
Source:https://arxiv.org/abs/2510.10468PreviousLearning Latent Volumetric Dynamics for Multimodal Goal-Conditioned Robot Manipulation of HairNextControllable Generative Trajectory Prediction via Weak Preference Alignment
Related posts
Introducing automatic version upgrades for AWS Glue jobs
0AWS Big Data Blog
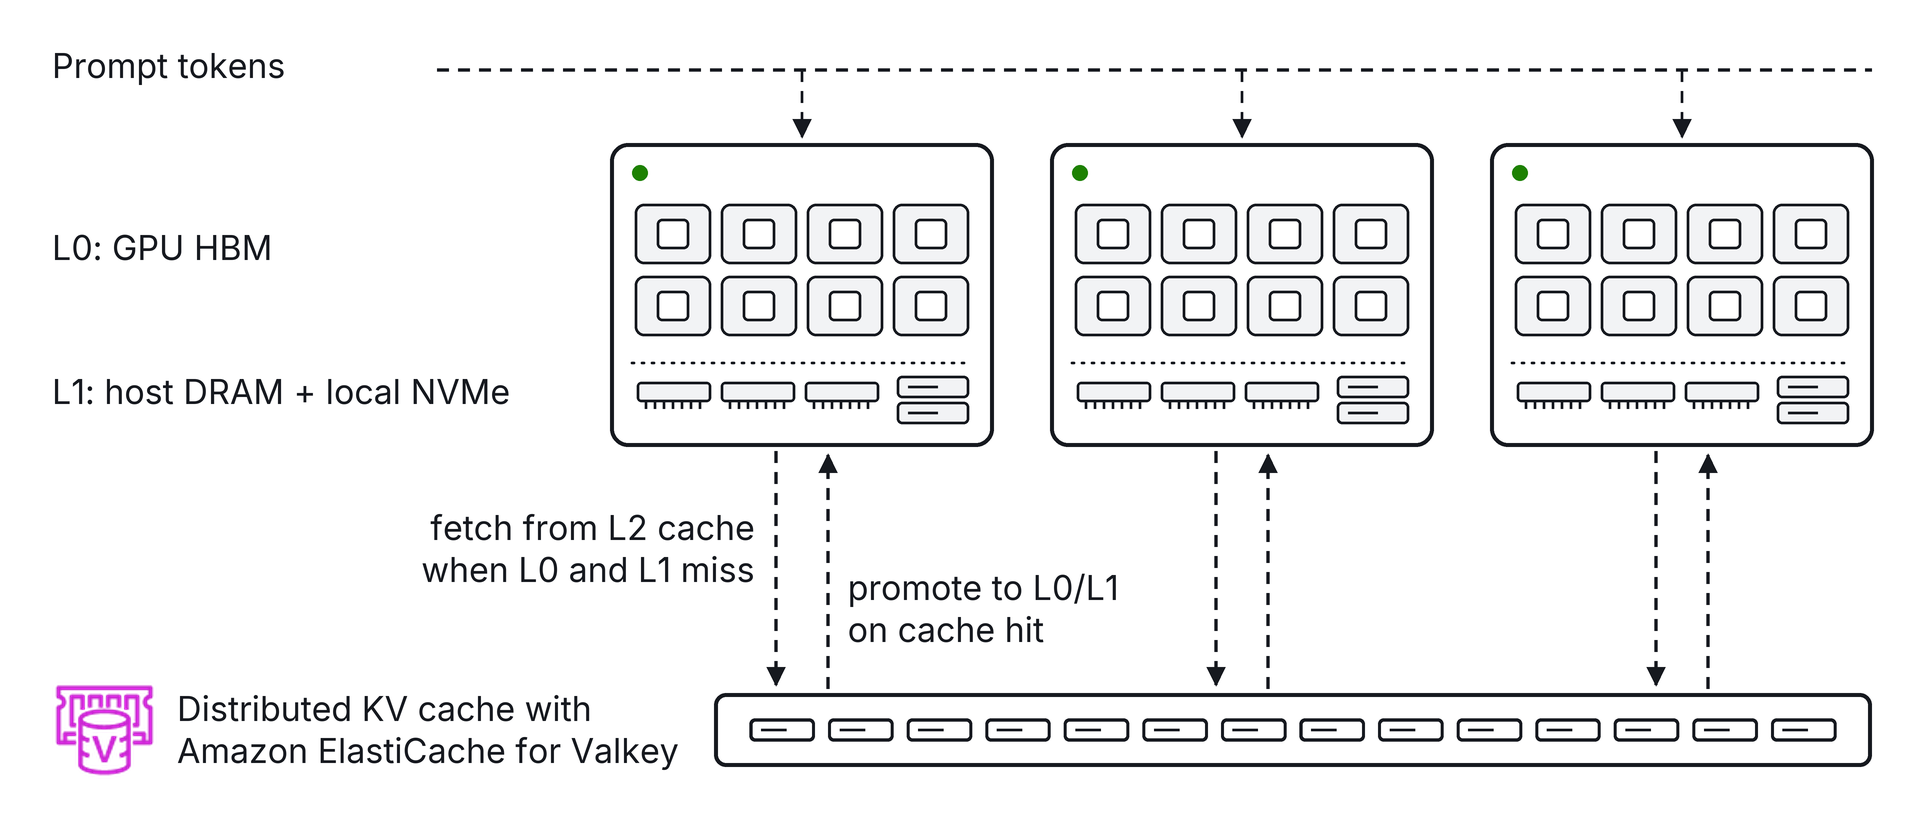
Announcing distributed KV caching for self-hosted LLMs with Amazon ElastiCache
0AWS Database Blog
Exa boosts embedding throughput by 50% to index billions of documents on AWS AI chips
0AWS Machine Learning Blog

BEVCast: Path-Adaptive BEV for Efficient End-to-End Autonomous Driving
0arXiv cs.RO

World-Model Gradient Refinement in CEM: An Empirical Study
0arXiv cs.RO

PRIME: Perception Feedback with Situational Memory Embeddings in VLA Models
0arXiv cs.RO