Backend
CommitFlow: Semantic Commitment Verification and Local Correction for Long-Horizon Robot Manipulation VLA Execution
arXiv cs.RO0 views
arXiv:2609.21908v2 Announce Type: replace Abstract: Although vision-language-action (VLA) policies have advanced rapidly, long-horizon execution may still progress to the next task stage before the required physical effect has been established. We call this a mismatch between semantic commitments, physical conditions that a stage must establish or maintain, and the actual physical state. Because an action command alone cannot confirm such a condition, local deviations can propagate and cause task failure. To address this problem, we present CommitFlow, a closed-loop execution framework that combines commitment monitoring with local correction while keeping the base policy frozen. CommitFlow integrates three components. A Semantic Commitment Monitor (SCM) compares stage requirements against current state evidence and holds back dependent actions when a required condition is unmet or violated. BoundaryFlow then generates a local correction conditioned on the current state and base action, and Relation and Gain Calibration (RGC) selects the smallest correction strength that satisfies the relevant constraints. Across the ten common RoboTwin 2.0 benchmark tasks, CommitFlow achieves a mean success rate of 75.9 percent, improving on the base policy pi0.5 by 22.7 percent. Cross-policy experiments show consistent gains, pointing toward reliable long-horizon robot execution.
Source:https://arxiv.org/abs/2609.21908PreviousOpenRoIS: A Community-Driven Open-Source Middleware Implementing the Robotic Interaction Service (RoIS) Framework for Physical Robots, Virtual Avatars, and Digital ServicesNextComparative Evaluation of an XR Pen-based Control Interface for Semi-Autonomous Mobile Robot Navigation in Service Environments
Related posts

Introducing Amazon OpenSearch Memory: Persistent memory for AI agents
0AWS Big Data Blog

How Social Department built culture-aware video discovery
0AWS Machine Learning Blog
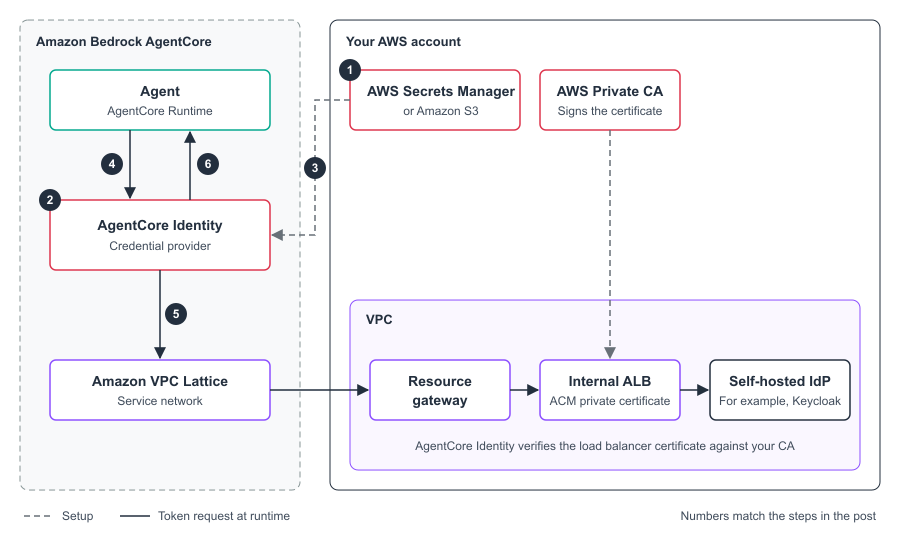
Private certificate authority support in Amazon Bedrock AgentCore Identity
0AWS Machine Learning Blog

OpenRoIS: A Community-Driven Open-Source Middleware Implementing the Robotic Interaction Service (RoIS) Framework for Physical Robots, Virtual Avatars, and Digital Services
0arXiv cs.RO

Navi-Agent: Unlocalized Monocular Navigation Agent
0arXiv cs.RO

Predictive safety filter enhanced curriculum learning control for efficient vehicle dynamics controller
0arXiv cs.RO