Backend
Navi-Agent: Unlocalized Monocular Navigation Agent
arXiv cs.RO0 views
arXiv:2609.20388v3 Announce Type: replace Abstract: Vision-Language Navigation in Continuous Environments (VLN-CE) requires an embodied agent to execute long-horizon instructions in unknown environments. Existing zero-shot VLN-CE systems typically maintain spatial states through geometric localization or coordinate-based representations. Recent geometry-constrained navigation removes depth and globally consistent coordinates, but maintaining persistent spatial awareness for place confirmation, progress verification, and recovery remains challenging. We present Navi-Agent, a zero-shot VLN-CE agent that constructs a coordinate-free spatial state from visual observations and executed motion histories. Navi-Agent organizes this state as a navigation topology, where nodes represent visual places and edges represent motion transitions. This representation enables observation-based approximate self-localization, task progress verification, and visual revisitation-based recovery. Navi-Agent performs closed-loop navigation by decomposing instructions into sub-goals, executing local visual navigation, and verifying visited places through the constructed spatial state. Experiments on zero-shot VLN-CE benchmark and real-world robot platforms show that Navi-Agent achieves state-of-the-art performance among geometry-constrained methods while remaining competitive with approaches relying on geometric localization.
Source:https://arxiv.org/abs/2609.20388PreviousHINT: Human-Intent Inception for Agentic Robot ManipulationNextOpenRoIS: A Community-Driven Open-Source Middleware Implementing the Robotic Interaction Service (RoIS) Framework for Physical Robots, Virtual Avatars, and Digital Services
Related posts

Introducing Amazon OpenSearch Memory: Persistent memory for AI agents
0AWS Big Data Blog

How Social Department built culture-aware video discovery
0AWS Machine Learning Blog
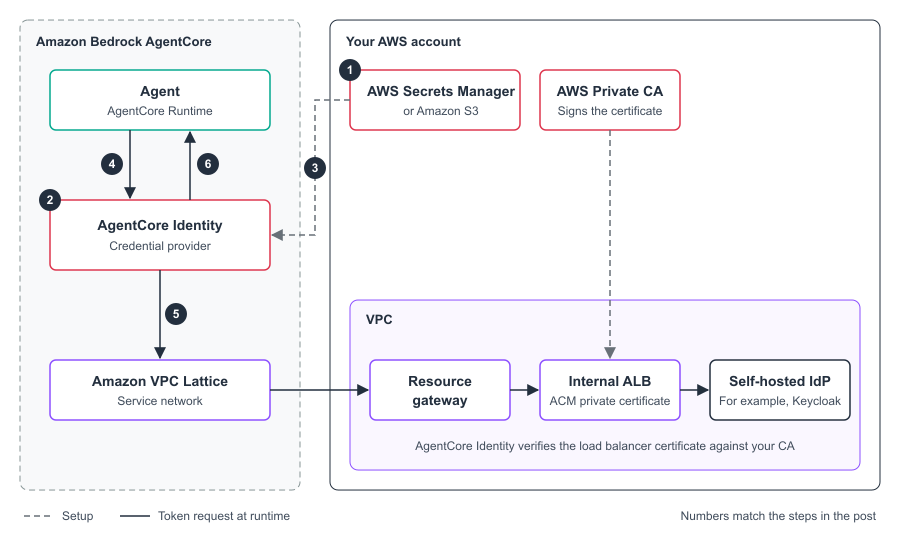
Private certificate authority support in Amazon Bedrock AgentCore Identity
0AWS Machine Learning Blog

CommitFlow: Semantic Commitment Verification and Local Correction for Long-Horizon Robot Manipulation VLA Execution
0arXiv cs.RO

OpenRoIS: A Community-Driven Open-Source Middleware Implementing the Robotic Interaction Service (RoIS) Framework for Physical Robots, Virtual Avatars, and Digital Services
0arXiv cs.RO

Predictive safety filter enhanced curriculum learning control for efficient vehicle dynamics controller
0arXiv cs.RO